
The transfer function of a system is given by, \(\frac{{{V_0}\left( s \right)}}{{{V_i}\left( s \right)}} = \frac{{1 - s}}{{1 + s}}\)
\(- \pi \;and\;0\)
The magnitude is unity and \(\phi(\omega)=\arg(1-j\omega)-\arg(1+j\omega)=-2\tan^{-1}\omega\). It tends from 0 at zero frequency to −π as frequency tends to infinity. Thus the lower and upper limiting phases are −π and 0.
Important Questions from Closed Loop Control Systems
In a closed loop automatic control system, the sequence of operations is as follows :
(i) Controlling unit
(ii) Correcting unit
(iii) Impact on the process
(iv) Measurement of process parametersThe block diagram of a control system in given below
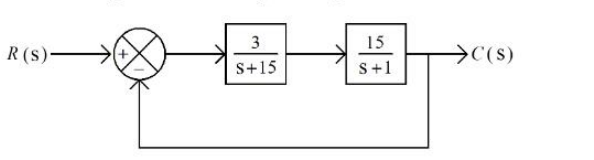
A. The root of characteristics equation is 6
B. The root of characteristics equation is -6
C. The root of characteristics equation is 5
D. The root of characteristics equation is -10
E. The root of characteristics equation is -5
Choose the most appropriate answer from the options given below :
The location of closed loop poles of a LTI system is given as shown in the figure :
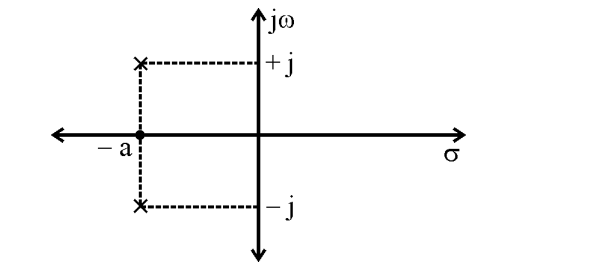
The system will be
A negative feedback control system whose open loop transfer function G(S) has feedback transfer function H(S) can be replaced by a single block with transfer function :
The effect of Tachometer feedback in a control system is to reduce -


