
The effect of Tachometer feedback in a control system is to reduce -
Time constant
Tachometer Feedback in Control Systems
A Tachometer is an electromechanical device designed to measure the rotational speed of a shaft and convert it into a proportional electrical signal, typically a voltage. In the context of a control system, Tachometer feedback involves using this voltage signal to modify the system's behavior. This type of feedback is often referred to as velocity feedback or derivative feedback because the signal is proportional to the rate of change of the output position (which is velocity). The primary goal of incorporating Tachometer feedback is to improve the dynamic performance and stability of the system.
How Tachometer Feedback Functions
- A Tachometer generator is mechanically coupled to the output shaft of the system, such as a motor in a position or speed control system.
- As the shaft rotates, the Tachometer produces an output voltage ($V_T$) that is directly proportional to the angular velocity ($\omega$) of the shaft, i.e., $V_T = K_T \omega$, where $K_T$ is the Tachometer constant.
- This generated voltage is then fed back to the input of the control system, usually in a negative feedback loop. It is typically subtracted from the reference input signal.
- By feeding back a signal proportional to the output velocity, the system can anticipate and damp out oscillations, leading to a more stable and faster response.
Effects of Tachometer Feedback on System Parameters
The introduction of Tachometer feedback has several crucial effects on the dynamic characteristics of a control system:
-
Time Constant: The time constant ($\tau$) of a system indicates how quickly it responds to a sudden change in its input. A smaller time constant means a faster response. Tachometer feedback effectively adds an internal damping force to the system. This additional damping helps to quickly settle the system's output, thereby reducing oscillations and making the system reach its steady-state value in a shorter amount of time. Consequently, the primary and most desirable effect of Tachometer feedback is a significant reduction in the effective time constant of the control system. This leads to an improved transient response, making the system more responsive.
For example, in a simple motor control system, the transfer function might be $\frac{K}{s(J_e s + B_e)}$. When velocity feedback ($K_T s$) is added, the new characteristic equation involves terms that effectively increase the damping constant, leading to a faster dominant pole response and a reduced effective time constant.
- Damping: Tachometer feedback is a powerful method for increasing the damping ratio of a system. Increased damping reduces overshoot and oscillations in the system's transient response, making it more stable. It acts similarly to viscous friction, resisting motion proportional to velocity, thereby absorbing energy and making the system settle faster without excessive ringing. Therefore, Tachometer feedback significantly increases damping.
- Gain: While Tachometer feedback is primarily used to improve dynamic response and stability, it can also influence the system's gain. By providing negative velocity feedback, it effectively reduces the low-frequency or steady-state gain of the system, which can, in turn, reduce steady-state errors due to velocity disturbances. However, its most direct and beneficial impact is on the transient performance, particularly the reduction of the time constant and increase in damping.
Analyzing the Given Options
Let's evaluate the options based on the established effects of Tachometer feedback:
- Option 1: Time constant – As discussed, Tachometer feedback is highly effective in reducing the time constant of the control system. This makes the system respond more quickly and efficiently to inputs.
- Option 2: Gain – While Tachometer feedback can influence gain (often reducing steady-state sensitivity or low-frequency gain), its most direct and celebrated dynamic effect is on improving transient response by affecting the time constant and damping.
- Option 3: Damping – This option states that Tachometer feedback reduces damping. This is incorrect. In fact, Tachometer feedback significantly increases damping, which is crucial for stability and reducing oscillations.
- Option 4: Both gain and damping – This option is incorrect because while Tachometer feedback might affect gain, it increases damping, it does not reduce it.
Based on the analysis, the most accurate and prominent effect of Tachometer feedback in a control system among the given choices is to reduce the time constant, thereby improving the speed of response.
Important Questions from Closed Loop Control Systems
In a closed loop automatic control system, the sequence of operations is as follows :
(i) Controlling unit
(ii) Correcting unit
(iii) Impact on the process
(iv) Measurement of process parametersThe block diagram of a control system in given below
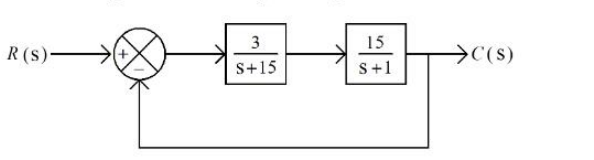
A. The root of characteristics equation is 6
B. The root of characteristics equation is -6
C. The root of characteristics equation is 5
D. The root of characteristics equation is -10
E. The root of characteristics equation is -5
Choose the most appropriate answer from the options given below :
The location of closed loop poles of a LTI system is given as shown in the figure :
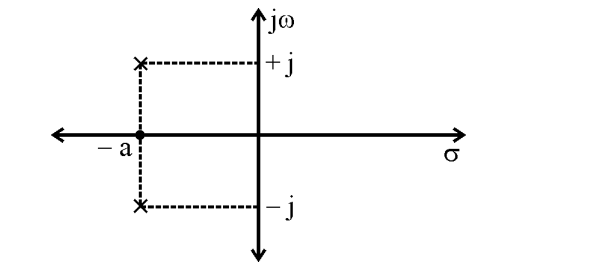
The system will be
A negative feedback control system whose open loop transfer function G(S) has feedback transfer function H(S) can be replaced by a single block with transfer function :
A linear time-invariant system initially at rest, when subjected to a unit step input, gives a response y(t) = te -t, t > 0. The transfer function of the system is:


