
The addition of a pole to the forward path transfer function of a closed loop system, generally has the effect of
Increasing the maximum overshoot
What a pole does to the loop. Adding a pole to G(s) inserts an extra lag: each pole contributes up to −90° of phase and an extra −20 dB/decade of roll-off. Both effects work against stability.
The frequency-domain reading. The extra phase lag pulls the open-loop phase curve down, so the phase crosses −180° at a lower frequency and the phase margin shrinks. Since phase margin and damping are tied together by the familiar rule of thumb
\(PM \approx 100\,\xi\ \text{degrees}\)
a smaller phase margin means a smaller damping ratio ξ. And overshoot rises steeply as damping falls:
\(M_p=e^{-\pi\xi/\sqrt{1-\xi^{2}}}\times100\%\)
so the maximum overshoot increases.
The root-locus reading, which shows the same thing. Adding a pole pushes the asymptotes of the root locus to the right: the centroid moves right and the asymptote angles widen, so the complex branches bend towards — and eventually into — the right half plane. The closed-loop poles therefore sit closer to the jω axis at any given gain, i.e. less damped, more oscillatory, larger overshoot, and the system becomes unstable at a lower gain.
The mirror-image result is worth learning alongside it: adding a zero to the forward path contributes phase lead, pulls the locus to the left, raises the phase margin and reduces the overshoot. That is precisely why a derivative or lead compensator (a zero) is used to tame an oscillatory system, while integral action (a pole at the origin) improves steady-state accuracy at the cost of transient behaviour.
| Added element | Phase | Root locus | Overshoot | Stability |
|---|---|---|---|---|
| Pole | lag | shifts right | increases | reduced |
| Zero | lead | shifts left | decreases | improved |
Hence, adding a pole generally has the effect of increasing the maximum overshoot.
Similar Questions
The step, ramp and parabolic test input signals can respectively be expressed as
Assertion (A) : In control systems, steady state response in the final requirement for calculating the efficiency of the system.
Reason (R) : The transient response is also critical for the determination of the steady state response.
If the characteristic equation of a closed loop system is S2 + 2S + 2 = 0, then the system is
The open loop transfer function of a unity feedback control system is given by \(G(s)=\frac{25}{s(s+5)}\). The natural frequency of oscillator is fixed.
Arrange the damped frequency of oscillation for the following damping ratio in ascending order
A. \(\xi = 0.5\)
B. \(\xi = 0.1\)
C. \(\xi = 0.3\)
D. \(\xi = 0.25\)
E. \(\xi = 0.4\)
Choose the correct answer from the options given below :
Match the following lists :
List - I List - II a. Negative real and simple roots i. Sustained oscillatory b. Negative real and equal roots ii. Overdamped c. Complex conjugate roots iii. Critically damped d. Imaginary conjugate roots iv. Underdamped Correct codes are :
consider a unity feedback control system for an open loop transfer function \(G(s)=\frac{5}{s(s+1)}\). Arrange the time constant in ascending order at different value of damping ratio of
A. \(\xi=3\)
B. \(\xi=7\)
C. \(\xi=1\)
D. \(\xi=10\)
E. \(\xi=5\)
Choose the correct answer from the options given below :
Important Questions from Time Response Analysis
Match the LIST-I with LIST-II
LIST-I
Transfer functionLIST-II
Step responseA. $\frac{25}{S^2+25}$ I. 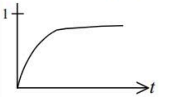
B. $\frac{36}{S^2+70S+36}$ II. 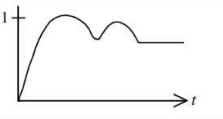
C. $\frac{36}{S^2+12S+36}$ III. 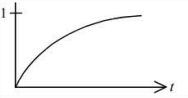
D. $\frac{36}{S^2+7S+49}$ IV. 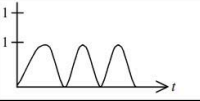
Choose the correct answer from the options given below:The step, ramp and parabolic test input signals can respectively be expressed as
Assertion (A) : In control systems, steady state response in the final requirement for calculating the efficiency of the system.
Reason (R) : The transient response is also critical for the determination of the steady state response.
If the characteristic equation of a closed loop system is S2 + 2S + 2 = 0, then the system is
The open loop transfer function of a unity feedback control system is given by \(G(s)=\frac{25}{s(s+5)}\). The natural frequency of oscillator is fixed.
Arrange the damped frequency of oscillation for the following damping ratio in ascending order
A. \(\xi = 0.5\)
B. \(\xi = 0.1\)
C. \(\xi = 0.3\)
D. \(\xi = 0.25\)
E. \(\xi = 0.4\)
Choose the correct answer from the options given below :



